
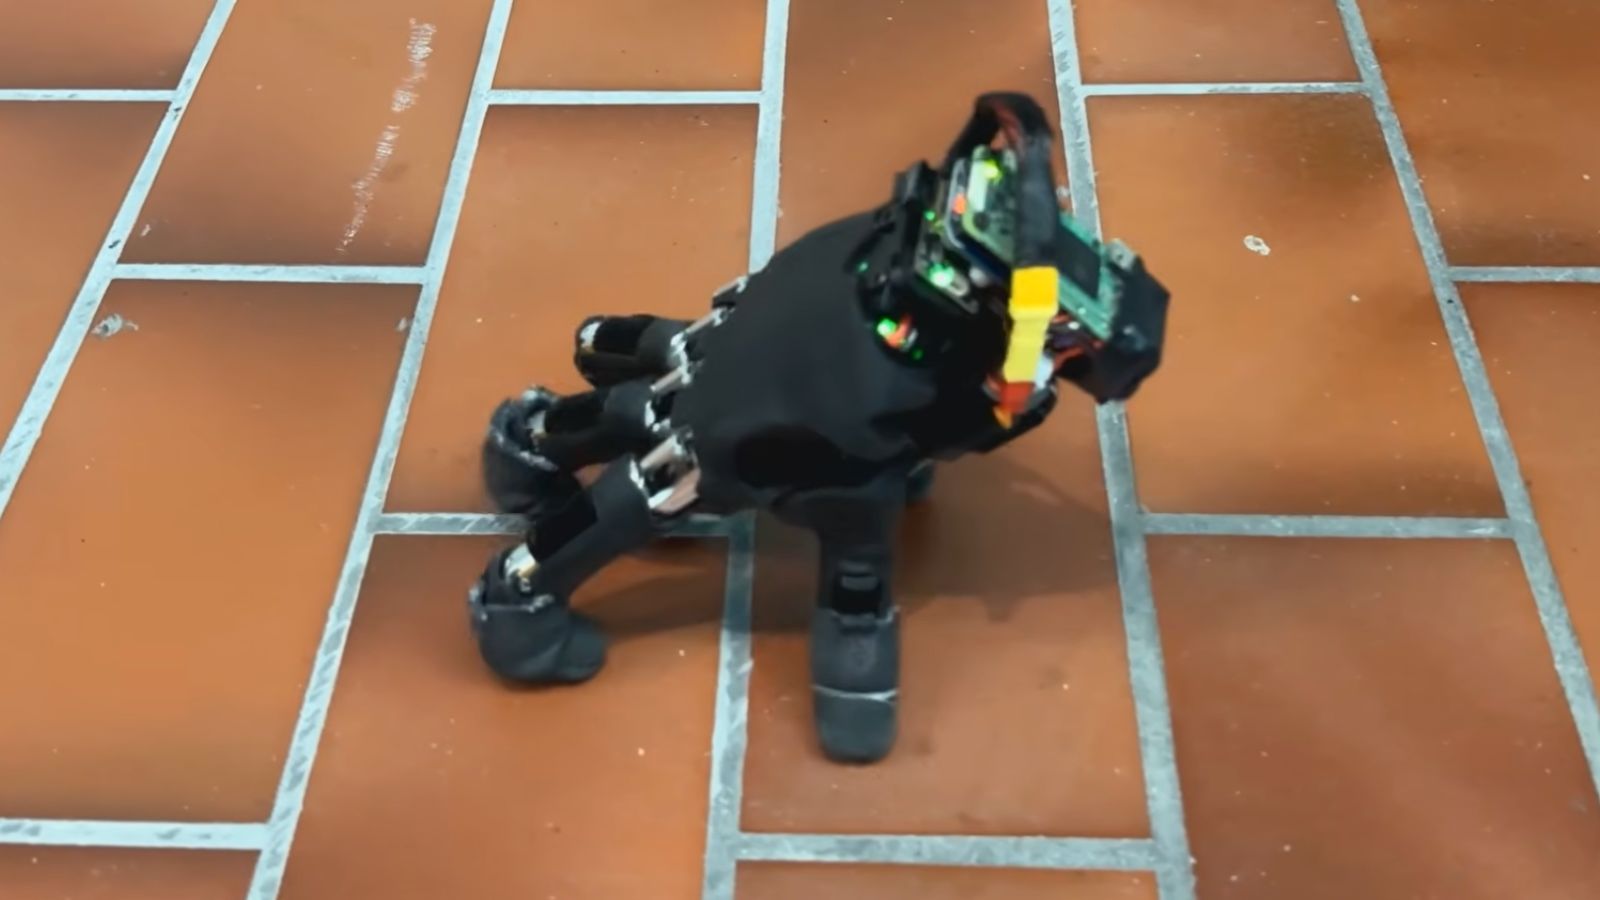
Unless you’re a massive Addams Family fan, there’s not really a reason to make a robot that looks (and works) like a disembodied hand. Okay, fine, you might also be an Evil Dead fan, specifically the second film. Or you might be looking to make humanoid robots even harder to kill, we suppose.
Whatever the folks at ETH Zurich’s Soft Robotics Lab’s reasons, they’ve gone and taught a robot hand to crawl around by itself. We’re as impressed as we are terrified, imagining successfully dismembering a crazed humanoid robot and then seeing its bits crawl after us anyway.
Talk to the hand
Even worse, the robot appendage more or less taught itself. It figured out how to “crawl, steer, recover from falls, press keys, and push objects while supporting its own weight” via reinforcement learning. There’s a reason for this, beyond scaring the bejeebers out of people. Obviously.
Systems engineer Lawrence Kincheloe explains in the university’s YouTube video comments: “Imagine a robot hand that tracks internal performance and dynamically adapts to a damaged section of it’s [sic] range of motion, so it carries a limp, but can still perform its tasks, all done without having to re-calibrate and train the robot!”
Which… isn’t far off from our nightmare scenario. The training and learning done here could well see a crippled robot recover from its injuries to continue a task. If it’s building a Mars habitat for humans to visit, that’s cool. If it’s hunting down the dregs of humanity, that’s less fun. It would be amusing to stick these onto military models and have them scamper around enemy strongholds, breaking things. That’s more or less the plot of Jessica Alba’s Idle Hands.